Alumni | People | PhD Students
Numan Khurshid
Numan is a senior PhD Student in Computer Vision & Graphics Lab (cvglab) at LUMS Syed Babar Ali School of Science and Engineering.
Numan is a senior PhD Student in Computer Vision & Graphics Lab (cvglab) at LUMS Syed Babar Ali School of Science and Engineering.
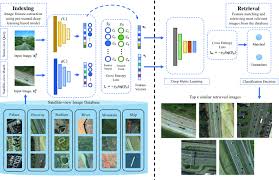
Three papers have been accepted at “International Conference on Neural Information Processing – 19 (ICONIP-19)”. This conference is ranked A by the CORE rating measure and is going to be held from 12th to 15th December 2019 in Sydney, Australia. “Cross-view Image Retrieval – Ground to Aerial Image Retrieval through Deep Learning” “Patch-based Generative Adversarial Network…
M Fakhir Khan was a Research Assistant in Computer Vision Lab (cvlab) at LUMS Syed Babar Ali School of Science and Engineering. Research Interest M. Fakhir Khan received the B.S. degree in Mechatronics and Control Engineering from the University of Engineering and Technology, Lahore, Pakistan, in 2015, and the M.S. degree in Electrical Engineering from…

Numan Khurshid, Mohbat Tharani, Murtaza Taj, and Faisal Qureshi Abstract: We propose a new method for remote sensing image matching. The proposed method uses encoder subnetwork of an autoencoder pre-trained on GTCrossView data to construct image features. A discriminator network trained on University of California Merced Land Use/Land Cover dataset (LandUse) and High-resolution Satellite Scene…
Mohbat, Tooba Mukhtar, Numan Khurshid, and Murtaza Taj International Conference on Image Analysis and Processing (ICAIP), Trento, Itlay, September 9-13, 2019 Abstract Advancements in deep learning techniques caused a paradigm shift in feature extraction for image perception from handcrafted methods to deep methods. However, these deep features if learned through unsupervised methods bear large memory…
Challenging the dogma of Relevance Feedback in Content based Image Retrieval Systems with Deep Learning May, 2018 at 3:00 pm in Smart Room 9-105 SBASSE. Abstract Association of images to their content based similar images in a database, is quite a fascinating challenge specially on social media platform where billions of tagged and untagged images…

Talha Hanif Butt, Murtaza Taj Abstract: Camera calibration is a necessity in various tasks including 3D reconstruction, hand-eye coordination for a robotic interaction, autonomous driving, etc. In this work we propose a novel method to predict extrinsic (baseline, pitch, and translation), intrinsic (focal length and principal point offset) parameters using an image pair. Unlike existing…